Cybernetic Systems and Controls
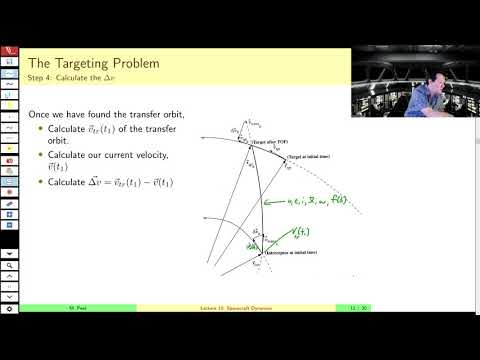
Given two position vectors and a required time of flight, Lambert's problem returns the connecting conic arc and hence the two impulses. It is the fallback used here whenever no base solution is time-feasible, and its delta-v serves as an upper bound against which the base-solution delta-v is the lower bound. Assumed at Section III.A and used numerically at Section VI.A, where the Lambert solution costs 6.047 km/s against a 5.5865 km/s base solution.