Cybernetic Systems and Controls
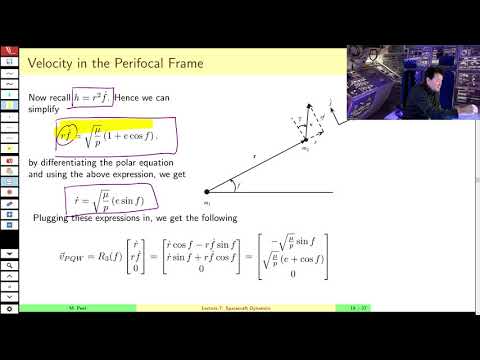
Converting orbital elements back into position and velocity vectors is the process of turning an orbit's shape and orientation angles into a satellite's actual location and speed in space, used after propagating an orbit forward in time to find where a satellite will be. The position and velocity are first written in the perifocal (PQW) frame, where the x-axis points toward periapsis, using formulas built from the semi-major axis, eccentricity, true anomaly, and angular momentum. They are then converted to Earth-Centered Inertial (ECI) coordinates by applying three rotation matrices in sequence, for right ascension of the ascending node, inclination, and argument of periapsis, in the reverse order used when the orbital elements were originally derived from ECI.